Numerical validation
Forced convergence
The forced benchmark applies a smooth three-axis body torque and compares the final state with a high-accuracy SciPy DOP853 solution integrated in quaternion and body-momentum coordinates.
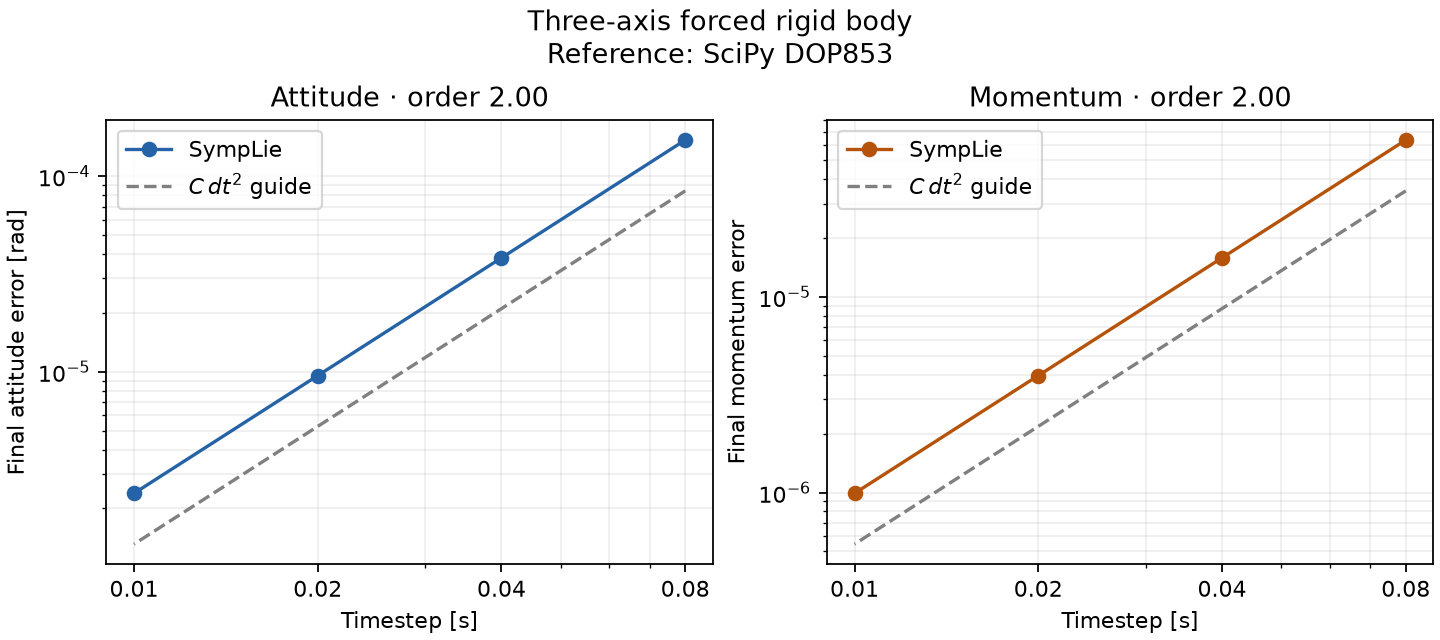
Halving the timestep reduces both attitude and momentum error by approximately four. The observed orders are 2.00 for both quantities.
Closed-loop attitude control
The geometric PD example regulates a large initial attitude error while damping angular velocity. Controller output is held constant between samples.
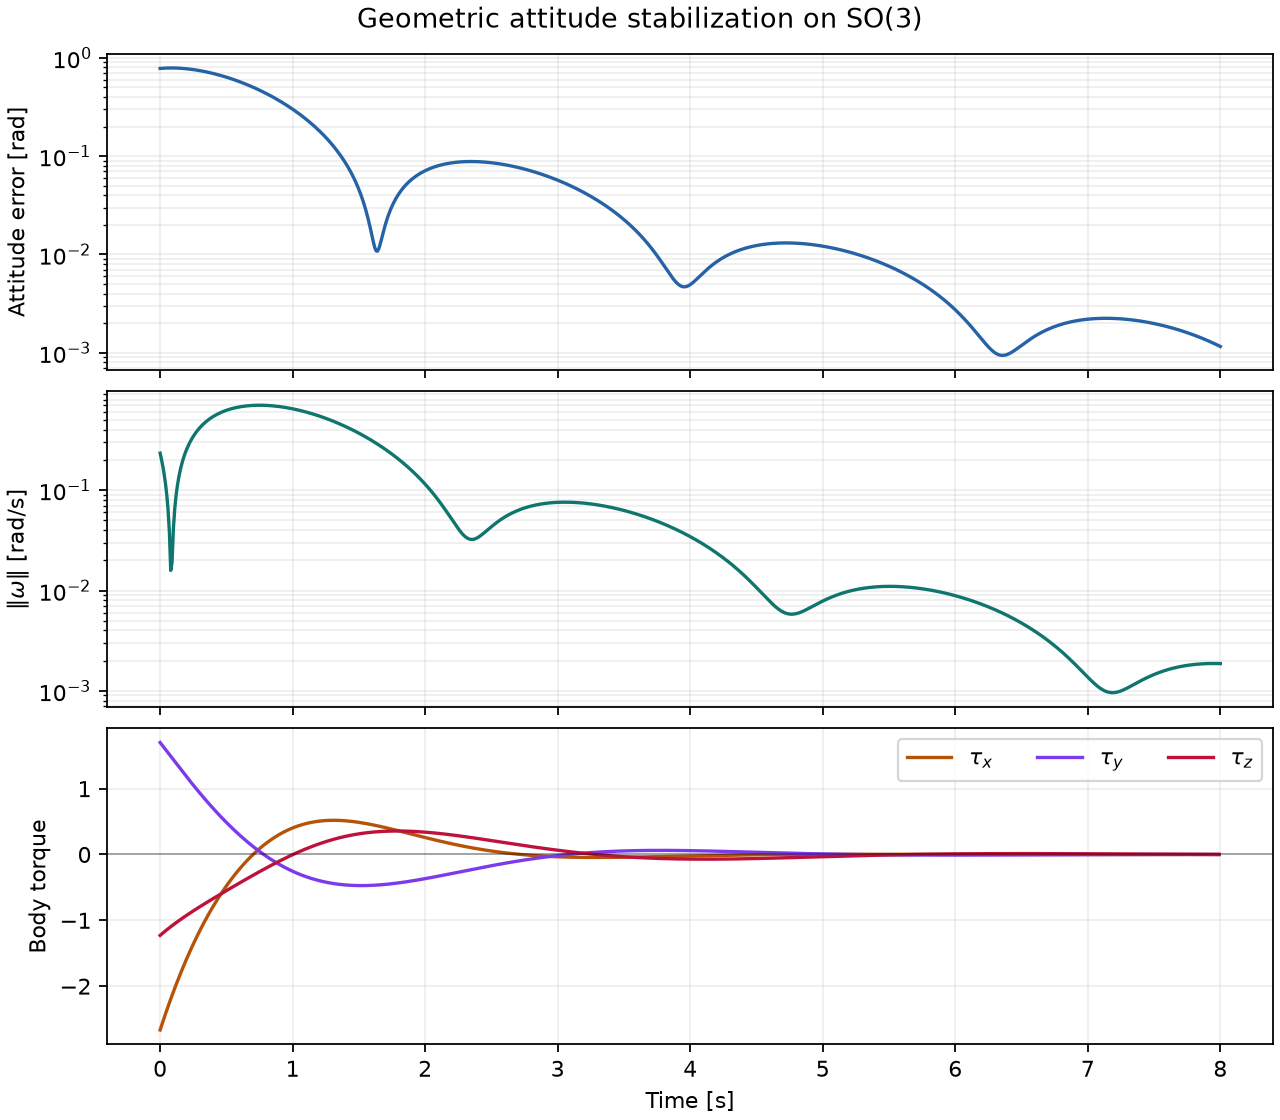
The plotted run reduces geodesic attitude error from \(0.781\) rad to \(1.15\times10^{-3}\) rad over eight seconds. Every nonlinear solve satisfies the configured residual tolerance.
Torque-free invariants
The torque-free update preserves spatial angular momentum algebraically. The repository retains the spatial-momentum comparison and energy comparison as supporting artifacts rather than headline figures.


All figure-generation scripts abort if a nonlinear solve fails its configured tolerance.
Reproducing the figures
python scripts/attitude_accuracy.py --out artifacts --docs-out docs/assets
python scripts/control_response.py --out artifacts --docs-out docs/assets
python scripts/make_plots.py --out artifacts